Publications
* Equal contribution † Corresponding author
2026
Fewer Tokens, Better Action: GPT-6 Astra Robot Agents with 14% Higher Success but 65% Fewer Tokens
An efficient code-execution framework for robot-use agents: the agent chains robot primitives in Python cells, raising success from 63.1% to 71.7% with 65% fewer input tokens. Achieves state-of-the-art on RoboDojo (51.6% success, 19.4 points above the previous best on the public leaderboard), and our GRPO-trained 4B Coder generalizes to unseen tasks (18.8% → 44.1%), outperforming Qwen3.5-27B.
2025
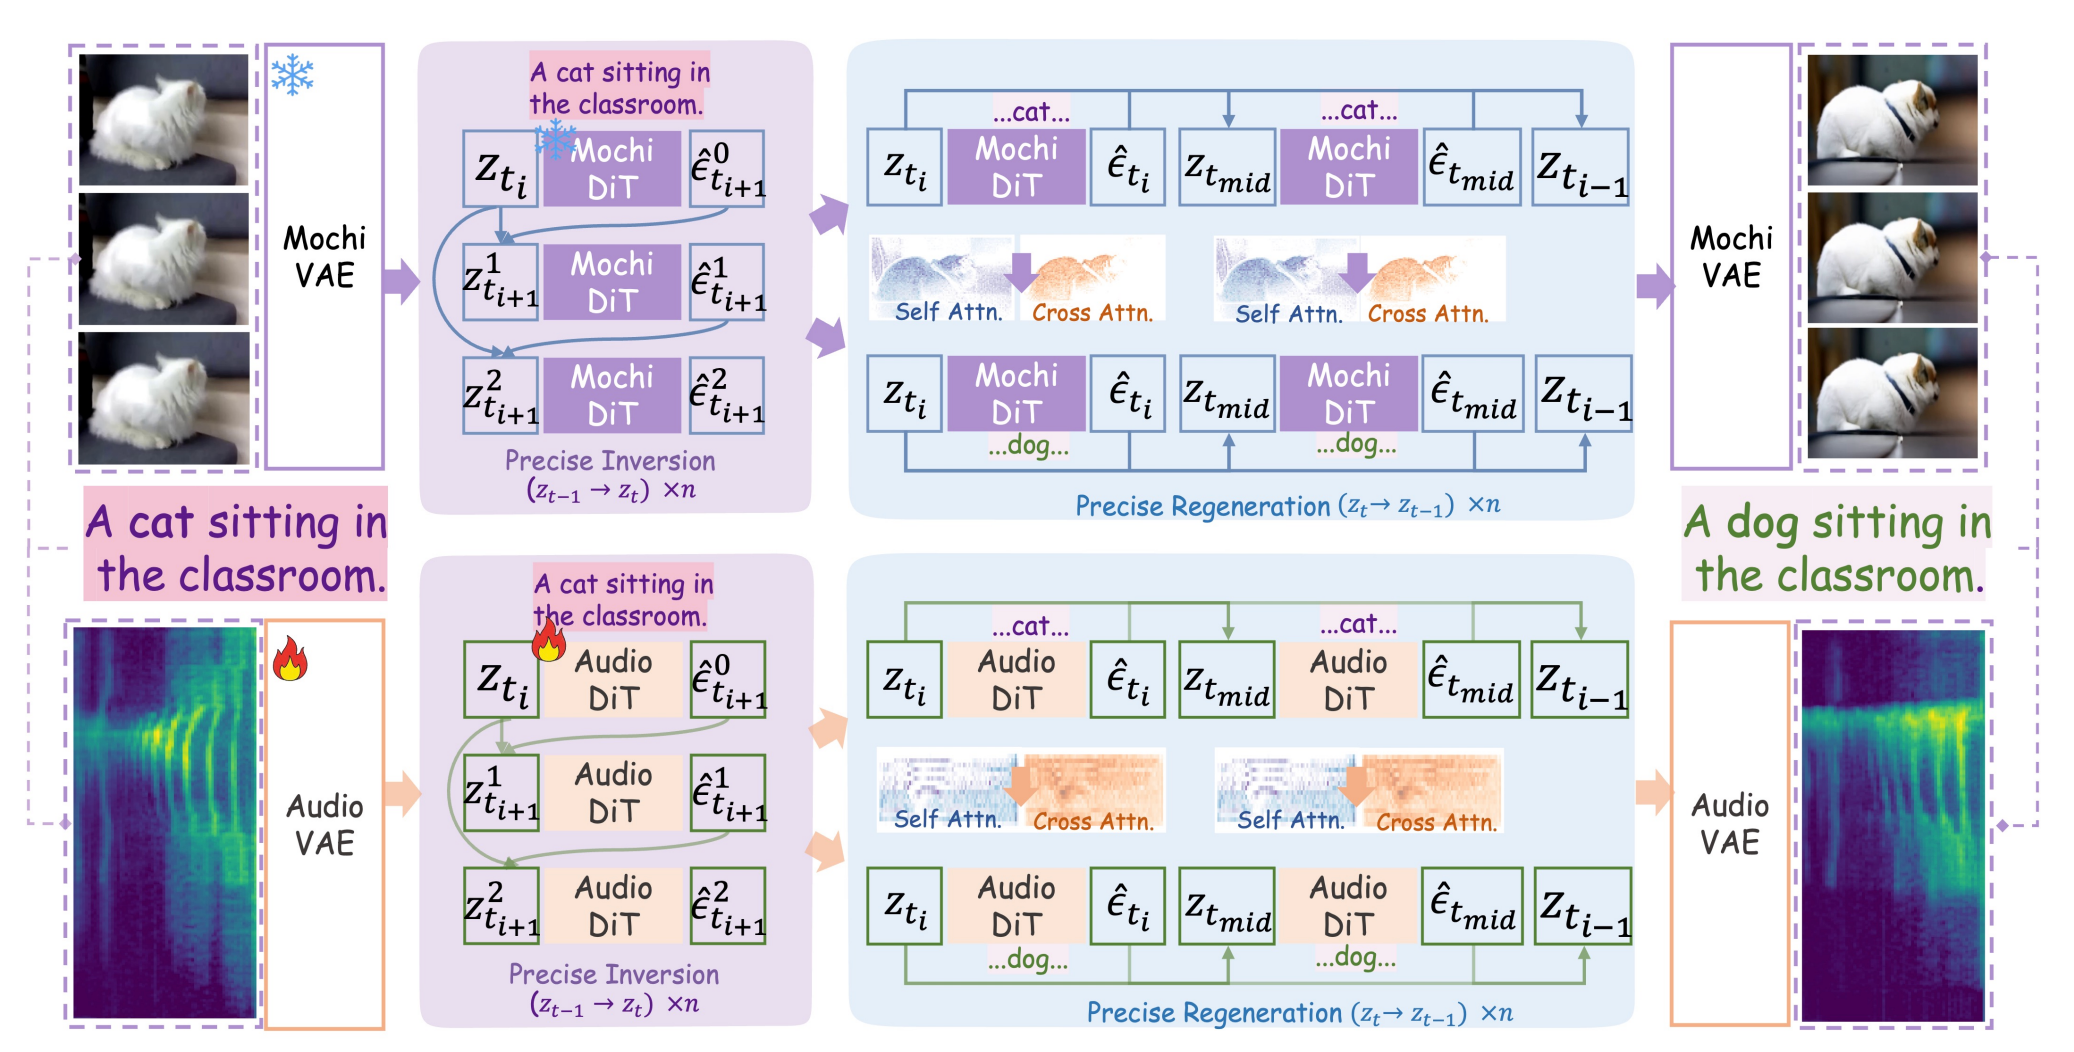
Object-AVEdit: An Object-level Audio-Visual Editing Model
We train an audio generation model whose text tokens are explicitly aligned with sounding objects, and build on it the first model for object-level audio-visual editing, supporting object addition, replacement and removal across both audio and video.